Complex engineering challenges may often require breaking larger goals into smaller, independent units. When operating in highly unfamiliar environments, autonomous systems might succeed by accepting unique physical constraints rather than forcing traditional methods.
Wikipedia's current-events log for September 22, 2018 recorded that robots successfully landed on asteroid Ryugu. JAXA reported that on September 21, the small compact MINERVA-II1 rovers separated from the Hayabusa2 spacecraft at 13:06 JST. The agency stated that MINERVA-II1 consists of two rovers, Rover-1A and Rover-1B. Furthermore, JAXA described MINERVA-II1 as the world’s first rover to land on the surface of an asteroid.
How Unconventional Design Choices Could Enable Operations in Uncharted Territory
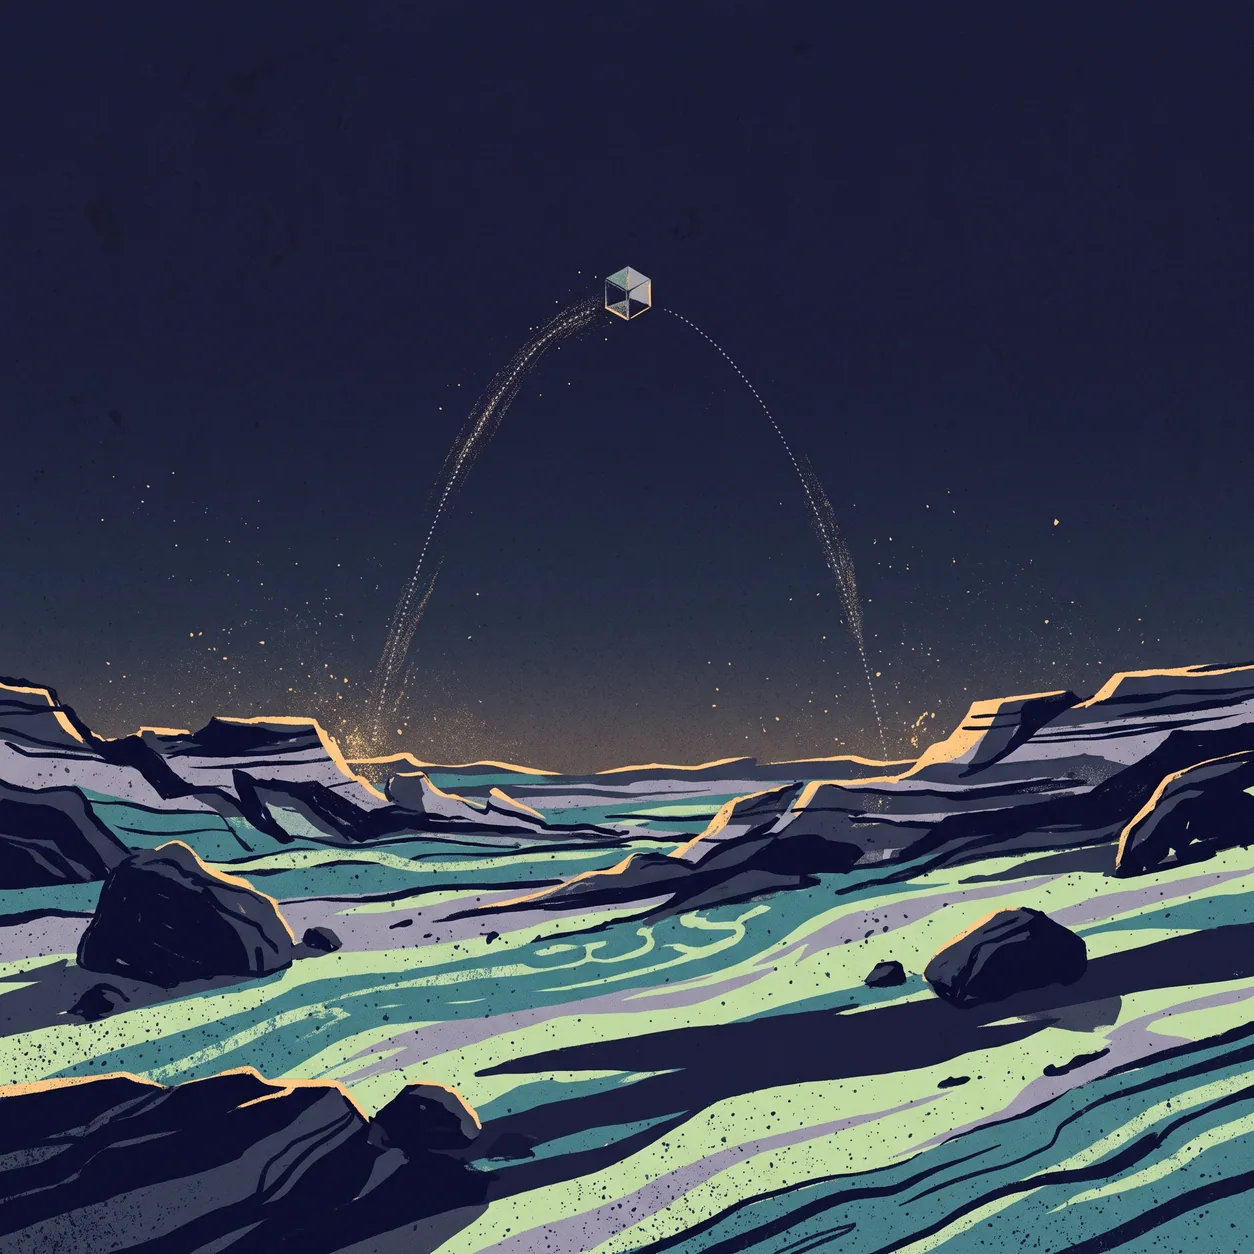
Designing for low-gravity environments can demand mechanisms that look fundamentally different from standard wheeled vehicles. When traditional traction might fail, bouncing or hopping mechanisms could offer a practical alternative for navigating irregular surfaces. Teams building hardware for unknown conditions might benefit from designing minimal, redundant mechanisms rather than complex, singular platforms.
Splitting a deployment into distinct sub-units may also provide risk mitigation. If one module encounters unexpected surface hazards, a secondary unit can potentially continue collecting data. This approach suggests that modular architectures could improve overall resilience when facing high environmental uncertainty.
Why Small Rovers Might Offer Lessons for Modern Systems Thinking
For software developers and roboticists, deployed hardware operating millions of miles away can highlight the importance of autonomy. Where direct control across vast distances may be impractical, machines might need to be trusted to execute localized actions independently. Systems built with lightweight protocols and targeted capabilities might adapt faster to real-world friction than heavy, feature-rich frameworks.
Ultimately, exploring remote planetary bodies can remind teams that unconventional environments might require unconventional mobility solutions. Reengineering basic assumptions about movement and control may open up possibilities across autonomous technology.
True innovation in extreme operational contexts might come from adapting movement itself to fit the landscape.
Sources
- Portal:Current events/2018 September 22 (revision 861588333) - Wikipedia, 2018-09-28
- MINERVA-II1: Successful image capture, landing on Ryugu and hop! | Topics | JAXA Hayabusa2 project - JAXA, 2018-09-22